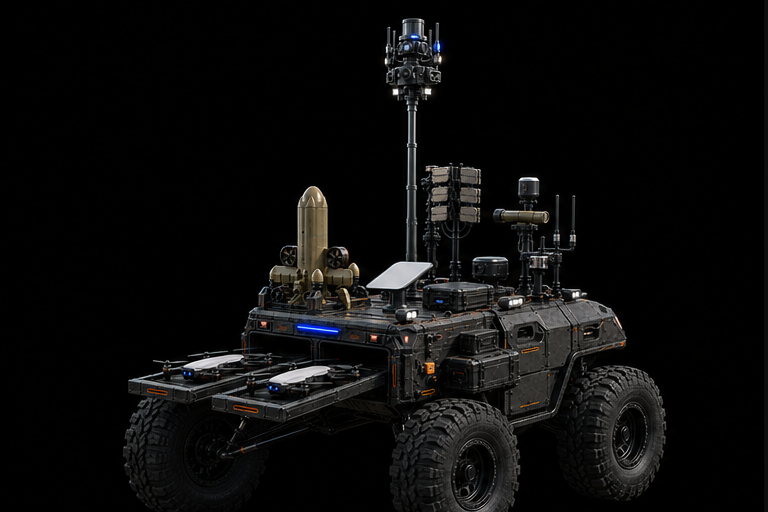
ARMP A2 autonomous robotic mobility platform
Autonomous Robotic Mobility Platform

Autonomy starts
where roads end.

One mobility architecture. Different missions. Built to carry serious payloads through terrain conventional machines struggle to reach.

~350°Independent steering
per wheel
36 inA2 total vertical
capability
500 kgA2 payload target
configuration-dependent
ROS 2Jetson-based autonomy
architecture
Prototype-stage engineering targets · concept configuration artwork
Platform family

Two platforms.
One mobility architecture.

A1 is the compact, multi-mission platform. A2 extends the architecture into deeper articulation and severe terrain.

ARMP A1
ARMP A1

Compact / Multi-Mission

350 kg payload target36 cm active travelUp to 50 km/h speed target
ARMP A2
ARMP A2

Severe Terrain / Outdoor

500 kg payload target24 in mechanical travel+12 in pneumatic adjustment
The payload changes. The A2 platform stays the same.
A2 platform

Same chassis.
Different mission systems.

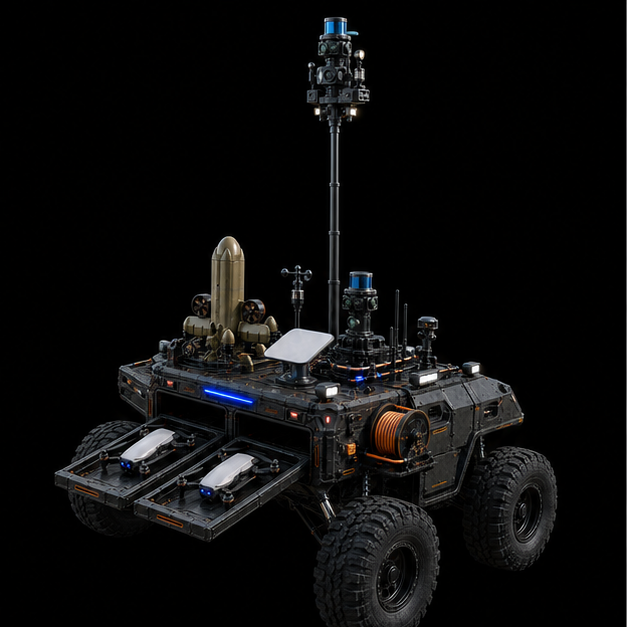
Switch configurations and views below. The goal is to show the common A2 mobility base clearly, then let the mission package tell the rest of the story.

A2 mission renders shown here share the same four-wheel mobility architecture. Sensors, mast, communications equipment and payload modules vary by configuration.
Mobility architecture

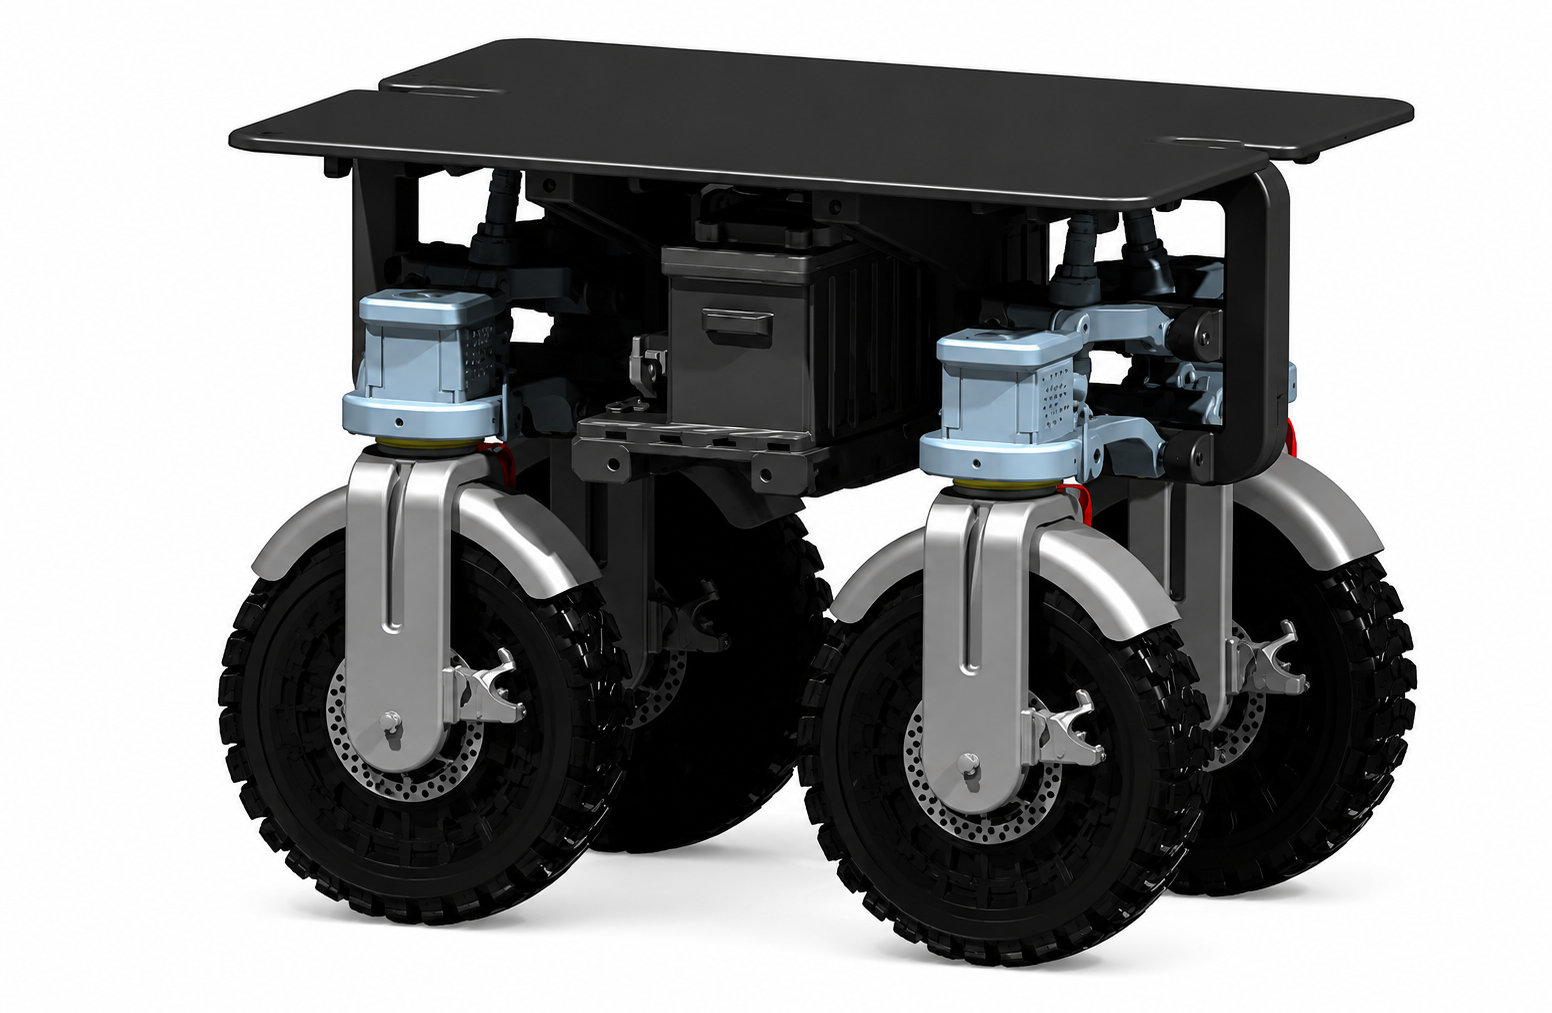
Every wheel is
its own system.

Steering, propulsion, torque allocation and suspension are controlled at the wheel/corner level so software can coordinate how the platform moves and holds its attitude over difficult terrain.
01Steer independently
02Drive independently
03Control torque independently
04Adapt suspension independently
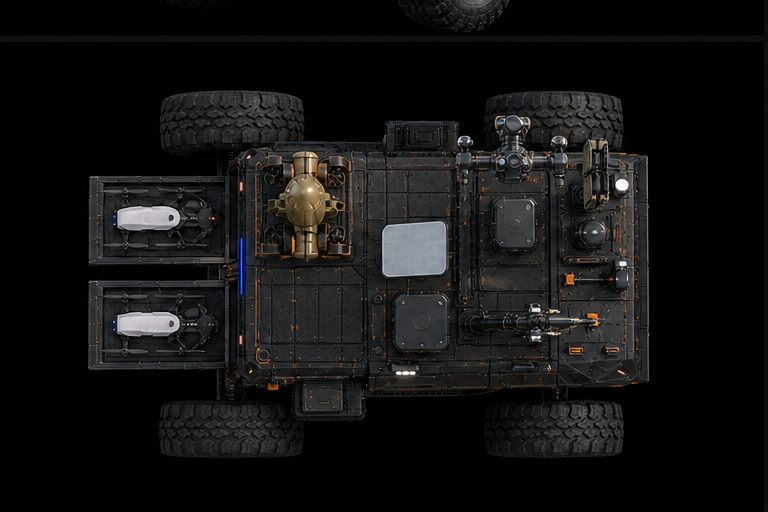
ARMP A2 top view
A2 · top architecture view
Perceive. Plan. Move. Adapt.
01

Perceive

Vehicle state, localization and environment sensing.

02

Plan

Terrain understanding and route selection.

03

Move

Independent wheel angle, speed and torque.

04

Adapt

Ride height, stability and vehicle response.

A2 configurations

Mission configured.
Mobility unchanged.

The platform becomes a carrier for different sensing, communications and support packages without redefining the mobility base.
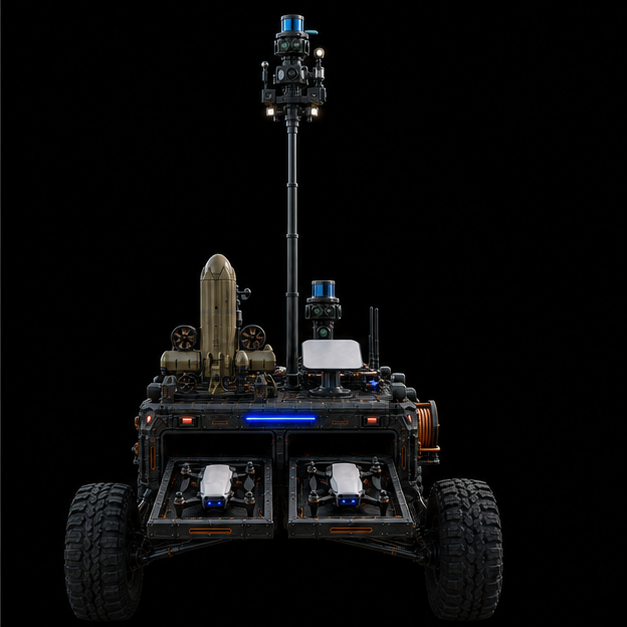
A2 Wildfire Support
Concept configuration

Wildfire Support

Elevated sensing, remote support and field communications package.
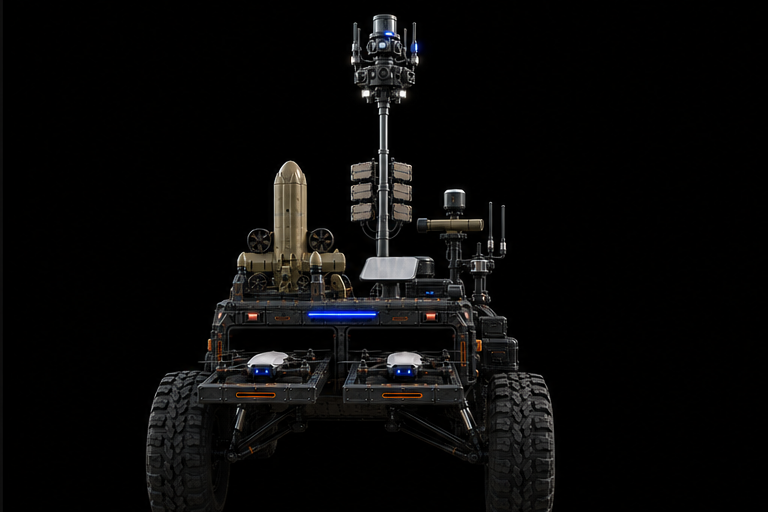
A2 ISR Communications
Concept configuration

ISR / Communications

Sensor mast, communications and autonomous remote operations package.
01

Defense

02

Logistics

03

Emergency Response

04

Remote Operations

XTY3 engineering
XTY3 Robotics · Canada

Engineering mobility
from the ground up.

XTY3 is developing autonomous robotic mobility platforms for difficult terrain, heavy payloads and modular missions—integrating mobility, active stability, sensing, compute and payload interfaces into one architecture.

ARMP A1 + A2Patent PendingNorth Vancouver, BC
XTY3 Robotics

Built for the ground
others can’t reach.

Talk to XTY3